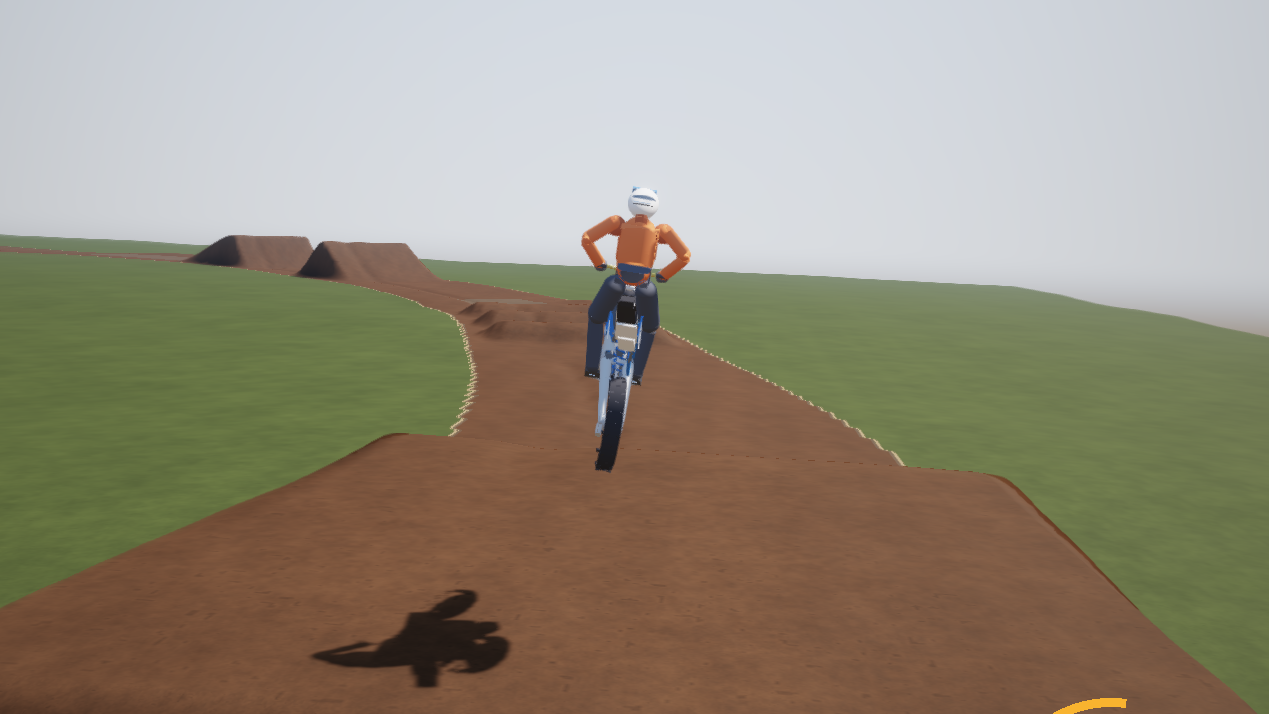
roost is a motocross simulator written from scratch in C++17 and OpenGL 4.5. There is no engine and there are no asset files: the bike, rider, track and every texture are generated from code.
The point is the physics. The bike is a real rigid body with a Pacejka tire model, suspension with its own unsprung mass, a 450cc driveline, and a rider whose weight shifts change the handling, in the air too. Physics runs at a fixed 1 kHz.
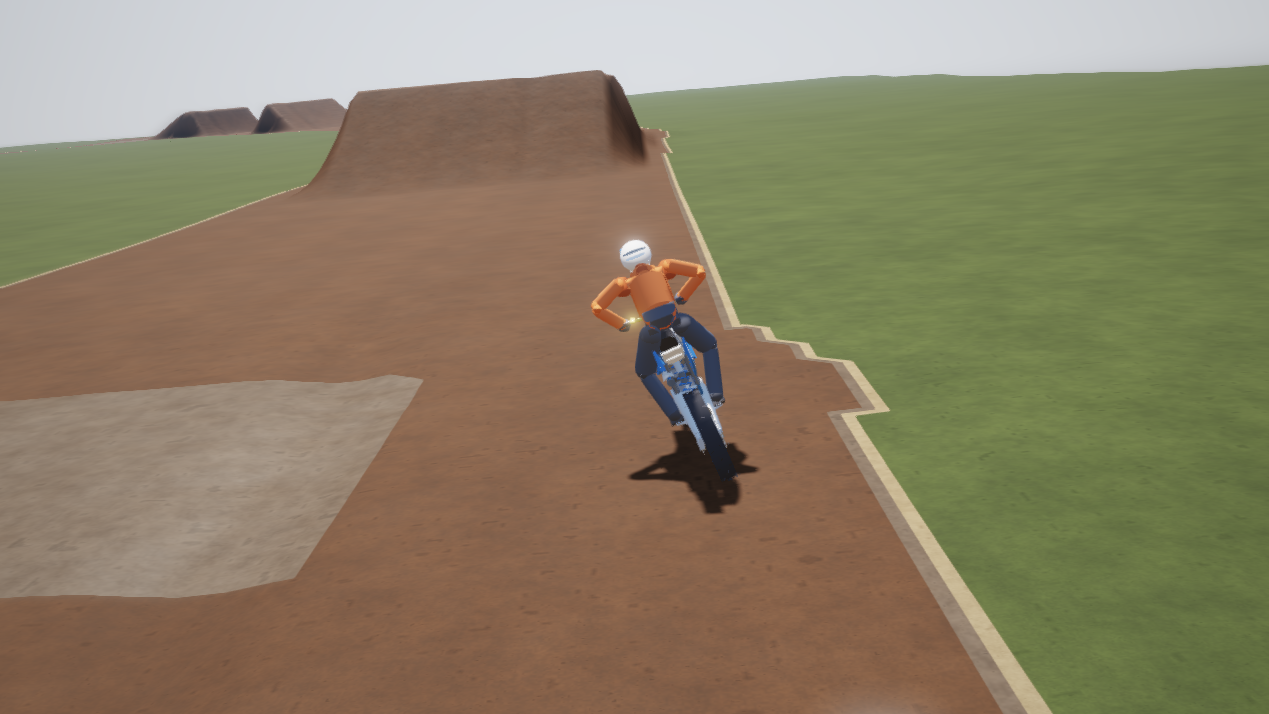
Both pictures are unedited frames from the game’s scripted rider.
Where it needs a person
A validation suite checks the simulation against real 450 motocross figures. One check fails: at about 10 m/s the bike can hold a 29° lean while barely turning, so it crabs instead of carving. High-speed cornering is consistent. The scripted rider also cannot finish a lap.
I need someone who rides, or who knows vehicle dynamics, to build it, ride it with a gamepad, and tell me what feels wrong. Build steps are in the repository README.